CANopen from the Raspberry Pi
Tutorial, ~20 min. You will use the HAT+'s MCP2515 as a Linux CAN interface and drive a motor satellite without the ESP32 master.
You need: Raspberry Pi 5 with HAT+ v2, 12 V supply, at least one motor satellite (node 11) on J102, bus terminated at both ends. Background: Architecture – two paths.
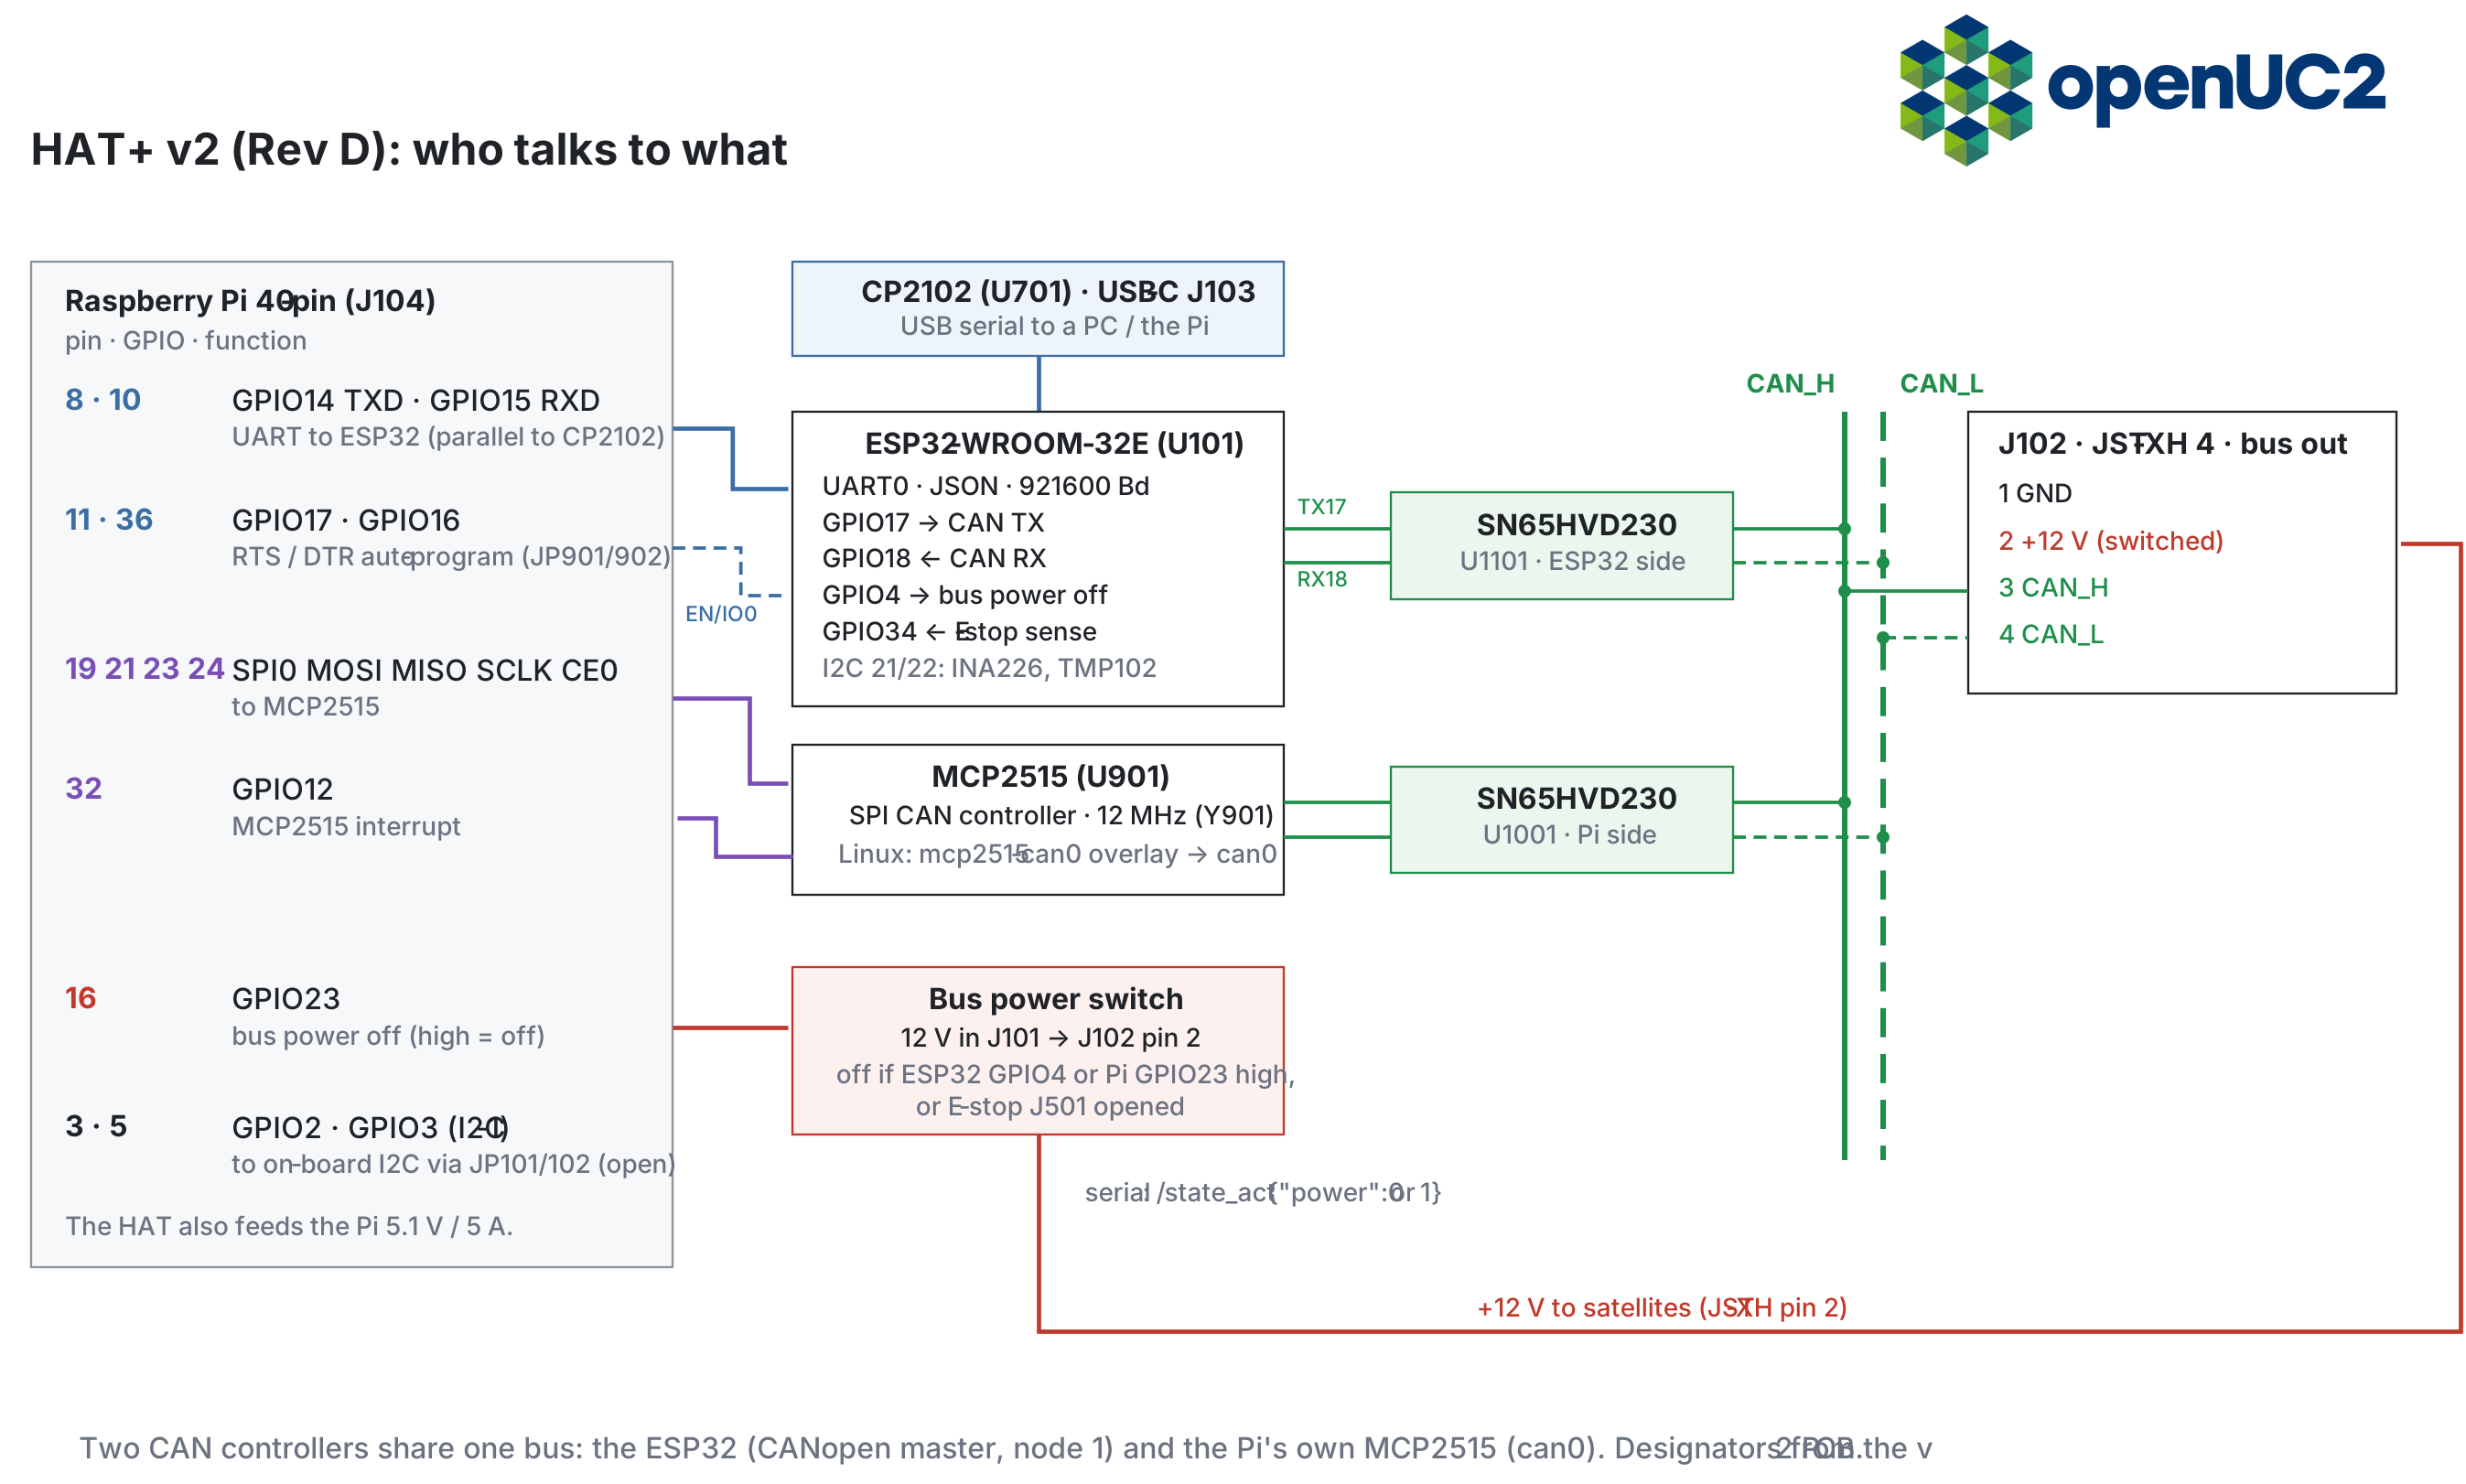
1. Enable the MCP2515
Add to /boot/firmware/config.txt and reboot:
dtparam=spi=on
dtoverlay=mcp2515-can0,oscillator=12000000,interrupt=12,spimaxfrequency=10000000
Check:
dmesg | grep -i mcp251 # "MCP2515 successfully initialized"
2. Bring up can0 at 500 kbit/s
sudo apt install can-utils
sudo ip link set can0 up type can bitrate 500000 restart-ms 100
ip -details link show can0  # state ERROR-ACTIVE
candump can0
Expected traffic within a second:
  can0  70B   [1]  05                    heartbeat of node 11 (0x05 = operational)
  can0  18B   [6]  00 00 00 00 02 00     TPDO1 of node 11: position, status, homing
  can0  701   [1]  05                    heartbeat of the ESP32 master
No frames → check bus power ({"task":"/state_act","power":1} on the ESP32, E-stop), termination and the 12 V supply.
3. Find the nodes
pip install uc2canopen
uc2can scan
Scanning for nodes (3.0s)...
Found 2 node(s): [1, 11]
4. Move the motor
import time
from uc2canopen import UC2Client

with UC2Client() as uc2:                                   # can0
    uc2.motor.move(axis=0, position=2000, speed=10000, node_id=11)
    time.sleep(0.05)                                       # let the first TPDO1 arrive
    uc2.motor.wait_for_idle(axis=0, node_id=11, timeout=10)
    print(uc2.motor.get_position(axis=0, node_id=11))     # 2000
    print(uc2.state.get_uptime(11), "s uptime")
candump shows the SDO writes on 0x60B and the replies on 0x58B, then TPDO1 frames with the running bit set until the motor stops.
5. Same move through the ESP32 (path A)
For comparison, send the JSON to the HAT's ESP32 (USB-C, 921600 Bd):
{"task":"/motor_act","qid":1,"motor":{"steppers":[{"stepperid":1,"position":0,"speed":10000,"isabs":1}]}}
Do not mix both paths on the same node at the same time.
What you learned
- The Pi's
can0is an ordinary SocketCAN interface at 500 kbit/s. - Satellites announce themselves with heartbeats (
0x700+n) and TPDO1 (0x180+n). - A move is a handful of SDO writes; completion is the running bit in TPDO1.