Electronics
Boards that run the UC2 ESP32 firmware (uc2-ESP). A host talks serial JSON to one board; boards talk CANopen to each other. Protocol, commands and Python clients: Serial & CANopen interface.
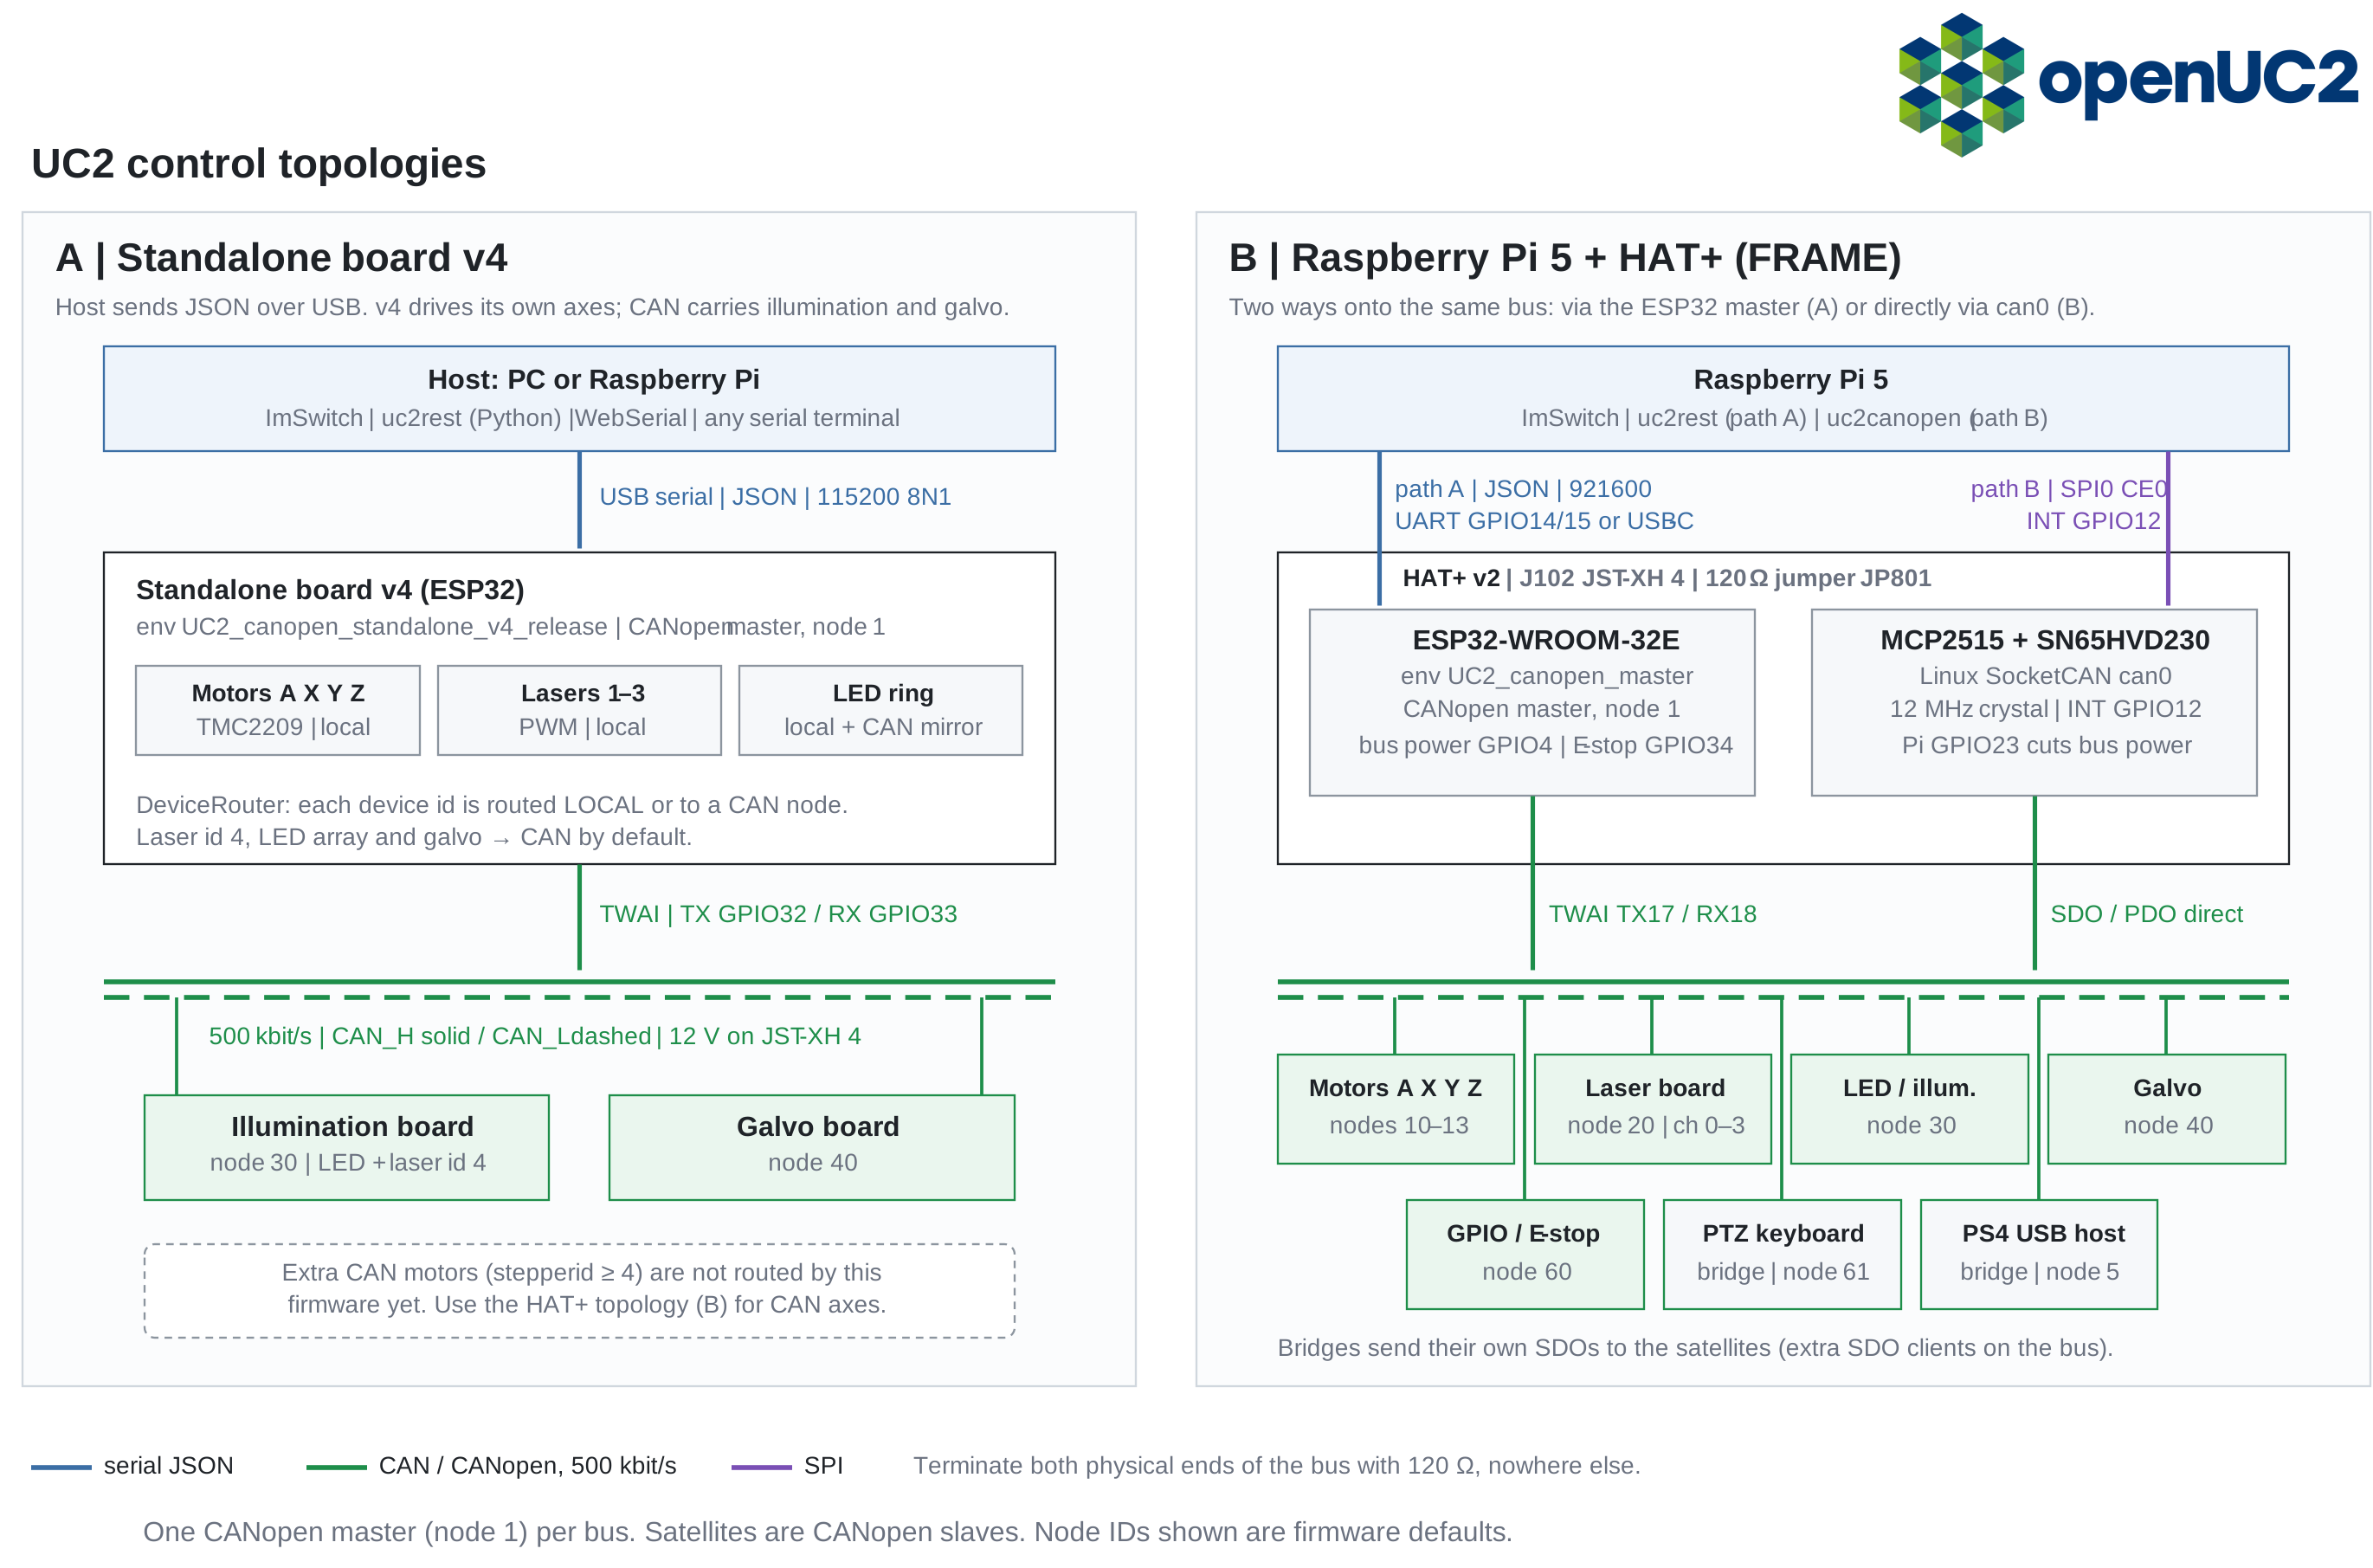
Available hardware interfaces
| Board | Role | Firmware env | Page |
|---|---|---|---|
| Standalone board v3 / v4 (ESP32 DevKit) | standalone, no CAN | UC2_3, UC2_4 | Standalone board |
| Standalone board v4 | CAN master, node 1 (hybrid: motors local, LED/galvo via CAN) | UC2_canopen_standalone_v4_release | Standalone board |
| HAT+ for Raspberry Pi 5 | CAN master, node 1 | UC2_canopen_master | HAT+: v1, v2 |
| Stepper backpack (XIAO ESP32-S3) | CAN satellite, motor A/X/Y/Z = node 10/11/12/13 | UC2_canopen_slave_motor | Stepper backpack |
| Laser interface (XIAO ESP32-S3) | CAN satellite, node 20 | UC2_canopen_slave_laser | FRAME electronics |
| LED / illumination (XIAO) | CAN satellite, node 30 | UC2_canopen_slave_led | Boards & node IDs |
| Galvo interface (XIAO) | CAN satellite, node 40 | UC2_canopen_slave_galvo | Boards & node IDs |
| PS4 controller | Bluetooth on standalone builds, or CAN bridge node 5 (DS4 on USB-OTG) | UC2_canopen_bridge_ps4_usbhost | PS4 controller |
FRAME electronics is the design reference for the HAT+, stepper backpack Rev C, laser interface and pogo-pin connectors.
Every board also accepts serial JSON on its own USB port: 115200 baud on the standalone board, 921600 on the HAT+ ESP32, USB-CDC (baud ignored) on XIAO satellites.
Bus
| Item | Value |
|---|---|
| Protocol | CANopen (CANopenNode), master = node 1 |
| Bitrate | 500 kbit/s, fixed |
| Connector | JST-XH 4, daisy-chained: 1 GND, 2 +12 V, 3 CAN_H, 4 CAN_L |
| Transceiver | SN65HVD230 (3.3 V), not isolated |
| Termination | 120 Ω at the two physical ends of the bus only |
Termination solder jumpers, all open by default:
| Board | Jumper |
|---|---|
| HAT+ v2 | JP801 |
| HAT+ v1 | JP1001 |
| Stepper backpack | JP502 |
| Laser interface | JP301 |
| Galvo interface | JP2001 |
Pins, node IDs and routing per env: Boards, roles & node IDs. Adding a board to the bus: Add a CAN satellite.